Robotic boiler packing line
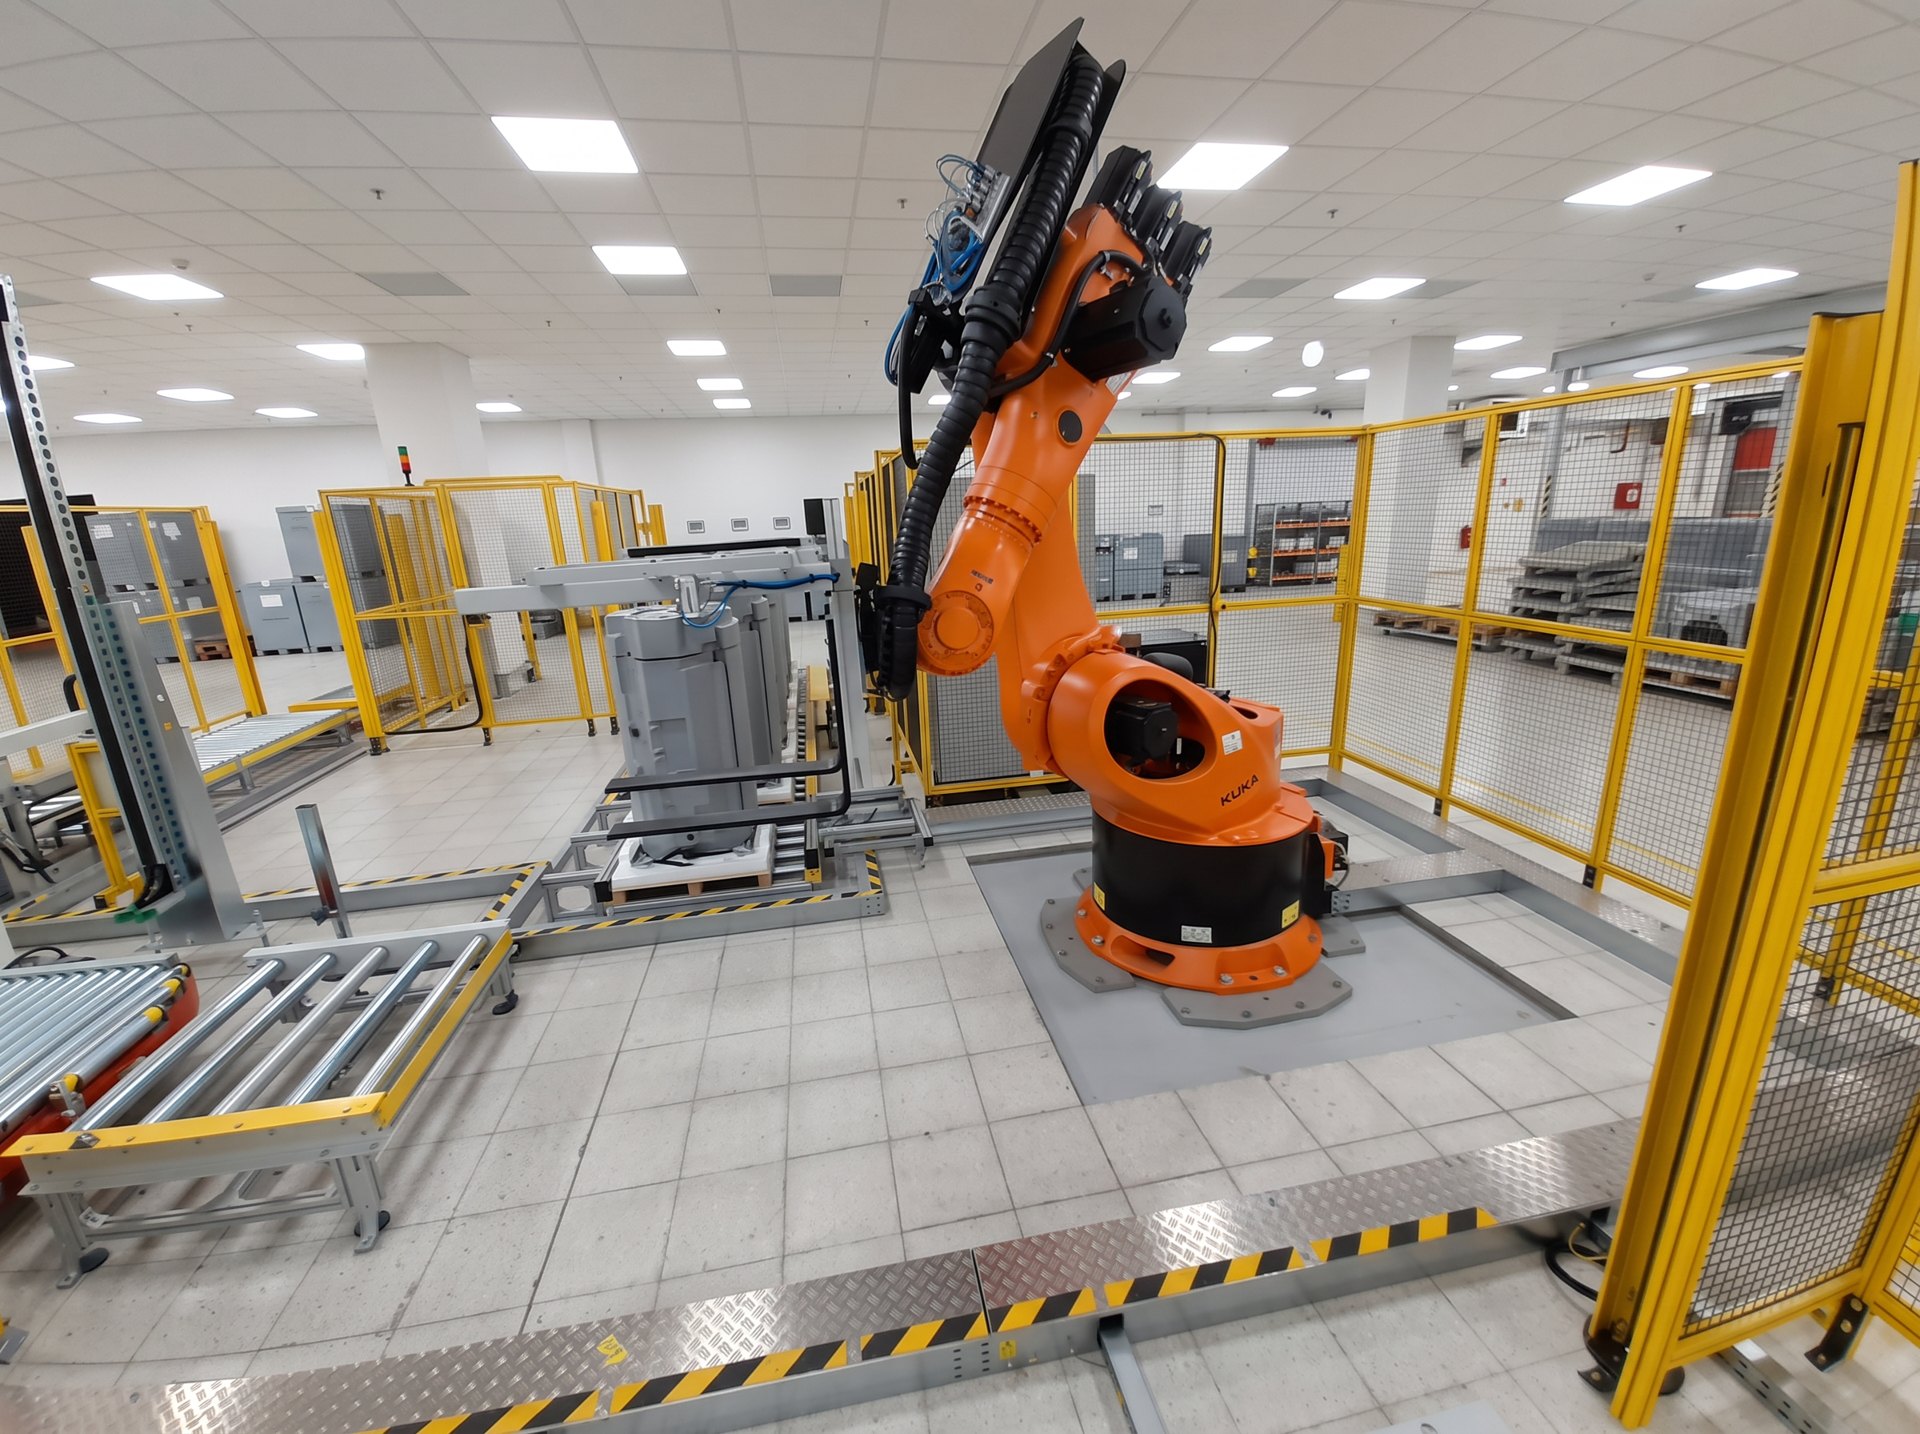
Project PQ221: AGV, a robot with a half-pallet gripper, docking stations and downstream boiler packing up to AGV pick-up.
Infeed and centring
An AGV delivers a partly assembled boiler base. Turntables move it onto conveyor 6, where a side pusher aligns and centres it for robotic gripping.
Gripper and docking
The boiler stands on a half pallet. The gripper forks enter from the side, lift the pallet, then pneumatic clamps secure the boiler and the robot gently tilts and transfers it. Two docking stations guide the cart into an exact position – an inductive sensor confirms seating and two pneumatic locks secure the cart.
Packing and dispatch
After final assembly the operator uses the HMI to move the finished boiler to position 2. The robot transfers it to the packing branch for strapping and wrapping, and a lift after turntable 10 lowers the packed product to AGV pick-up height.